Taiwanese Team Develops Dual-Arm Robot for Autonomous Hospital Bed Making
October 7, 2026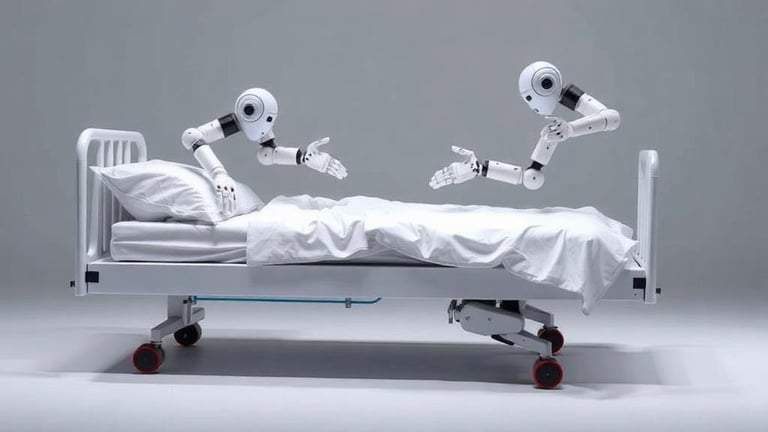

Building on deformable object manipulation and vision-language grounding, the work integrates perception, planning, and control into a hardware-tested system rather than relying on simulations.
The bed-making task is broken into twelve steps using a structured decomposition, enabling monitoring, evaluation, and recoveries at each stage.
The study appears in the International Journal of Intelligent Robotics and Applications (2026) by Chih-Hsuan Shih, Po-Hsun Cheng, and Yung-Yu Chuang (DOI: 10.1007/s41315-026-00597-w).
A Taiwanese research team built a dual-arm robot system that autonomously makes hospital beds, using semantic keypoints and a vision-language perception pipeline.
Semantic keypoints from open-vocabulary detection models identify fabric landmarks—like sheet corners and fold midpoints—to guide dual-arm manipulation.
The work positions deformable-object manipulation as a frontier in embodied AI with clear benefits for nursing staff and infection control, while noting ongoing technical hurdles.
A closed-loop recovery mechanism detects failed grasps, re-perceives, replans, and retries, achieving a 91.9% average step-wise success across all twelve stages on real hardware.
Future work includes adding tactile feedback to improve layer-state estimation and developing adaptive recovery strategies based on the cloth’s actual state.
Experiments show rigid manipulation is nearly perfect, while deformable manipulation—especially sheet folding—remains challenging due to perception and grasp uncertainty, with early layer discrimination as the main difficulty.
The project is supported by Taiwan’s National Science and Technology Council and the Industrial Technology Research Institute.
Summary based on 1 source
Get a daily email with more AI stories
Source
BIOENGINEER.ORG • Oct 7, 2026
Robots Learn to Make Hospital Beds Using Semantic Keypoints and Two Arms